Skip to content

Projects 4

Projects

Every project, newest first
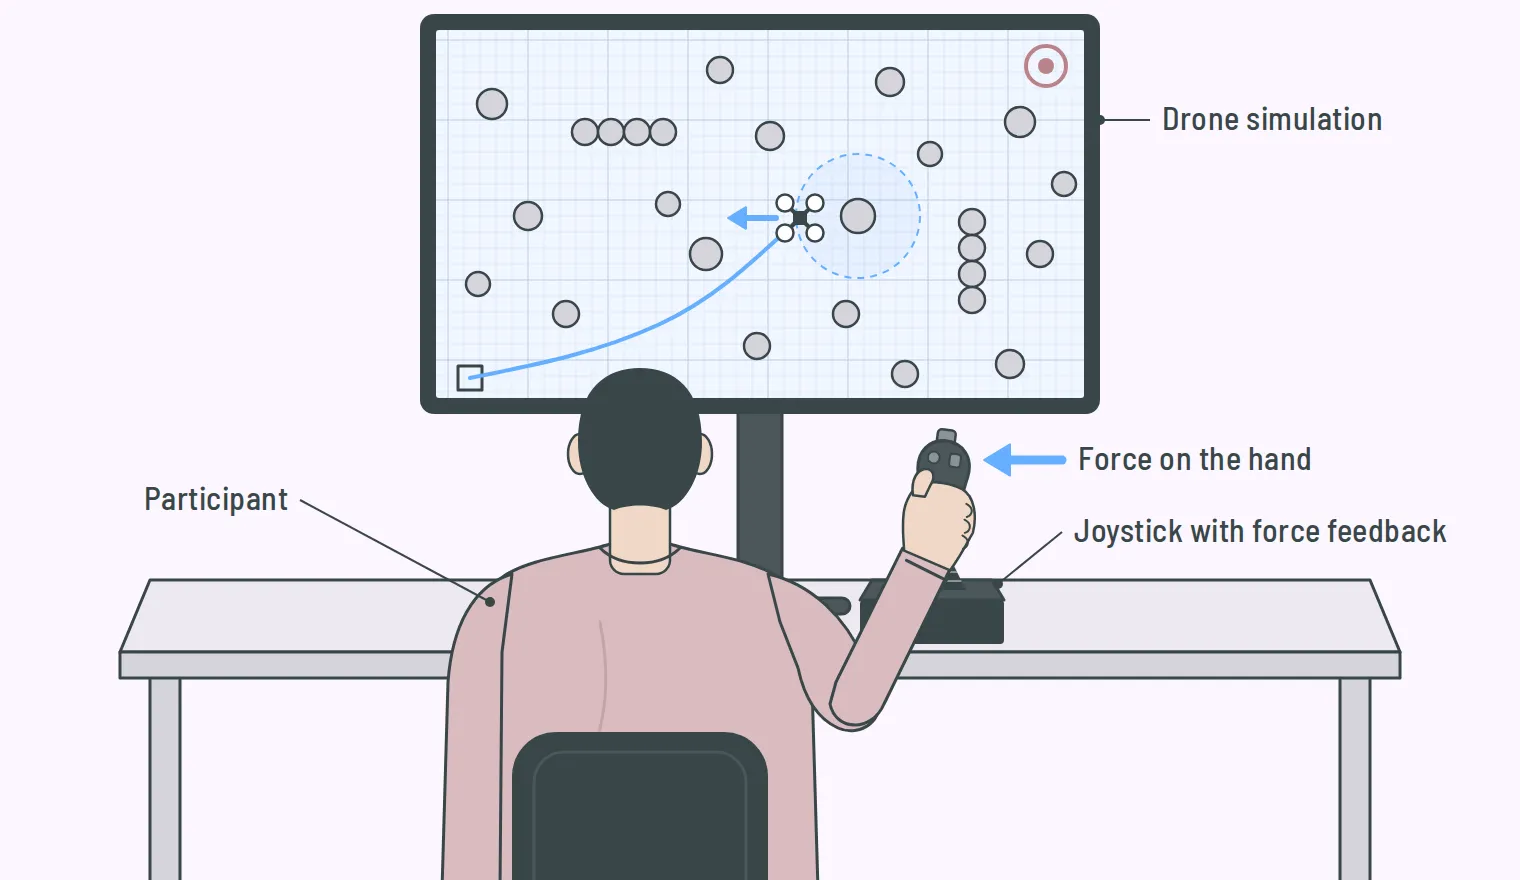
  1. Drawing of a participant from behind at a table. The participant holds a joystick with force feedback in the right hand. On the screen in front of them, a drone flies between circular obstacles towards a goal. A blue arrow at the joystick and one at the drone show the force that pushes away from the nearest obstacle.

    Scientific Paper - haptic feedback shared control

    User study on haptic forces on a joystick that help with steering a drone

    ROS 2, Python, Haptics, User study, Statistics, Software architecture

    2026-08
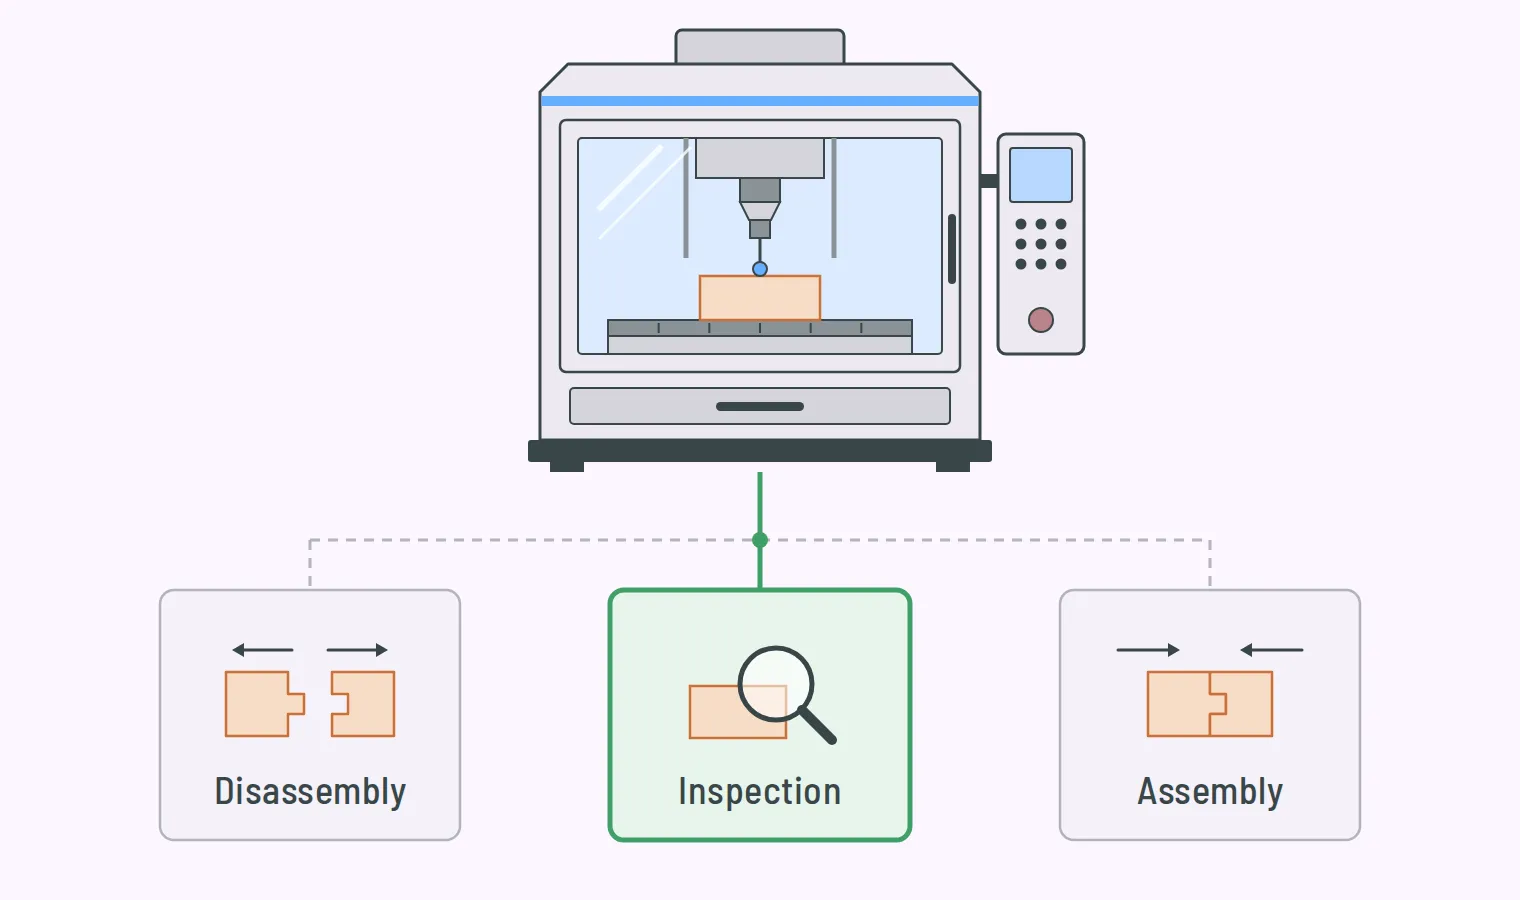
  2. Drawing of a production station in the form of a machine tool. Below it are the three processes it can be converted to: disassembly, inspection and assembly. Inspection is selected; it is outlined in green, and a measuring probe sits in the spindle.

    Reinforcement Learning for Circular Factories

    Reinforcement Learning, Software development, PPO, Graph-RL, PyTorch, Python

    Reinforcement Learning, Circular factory, Reconfiguration

    2026-07
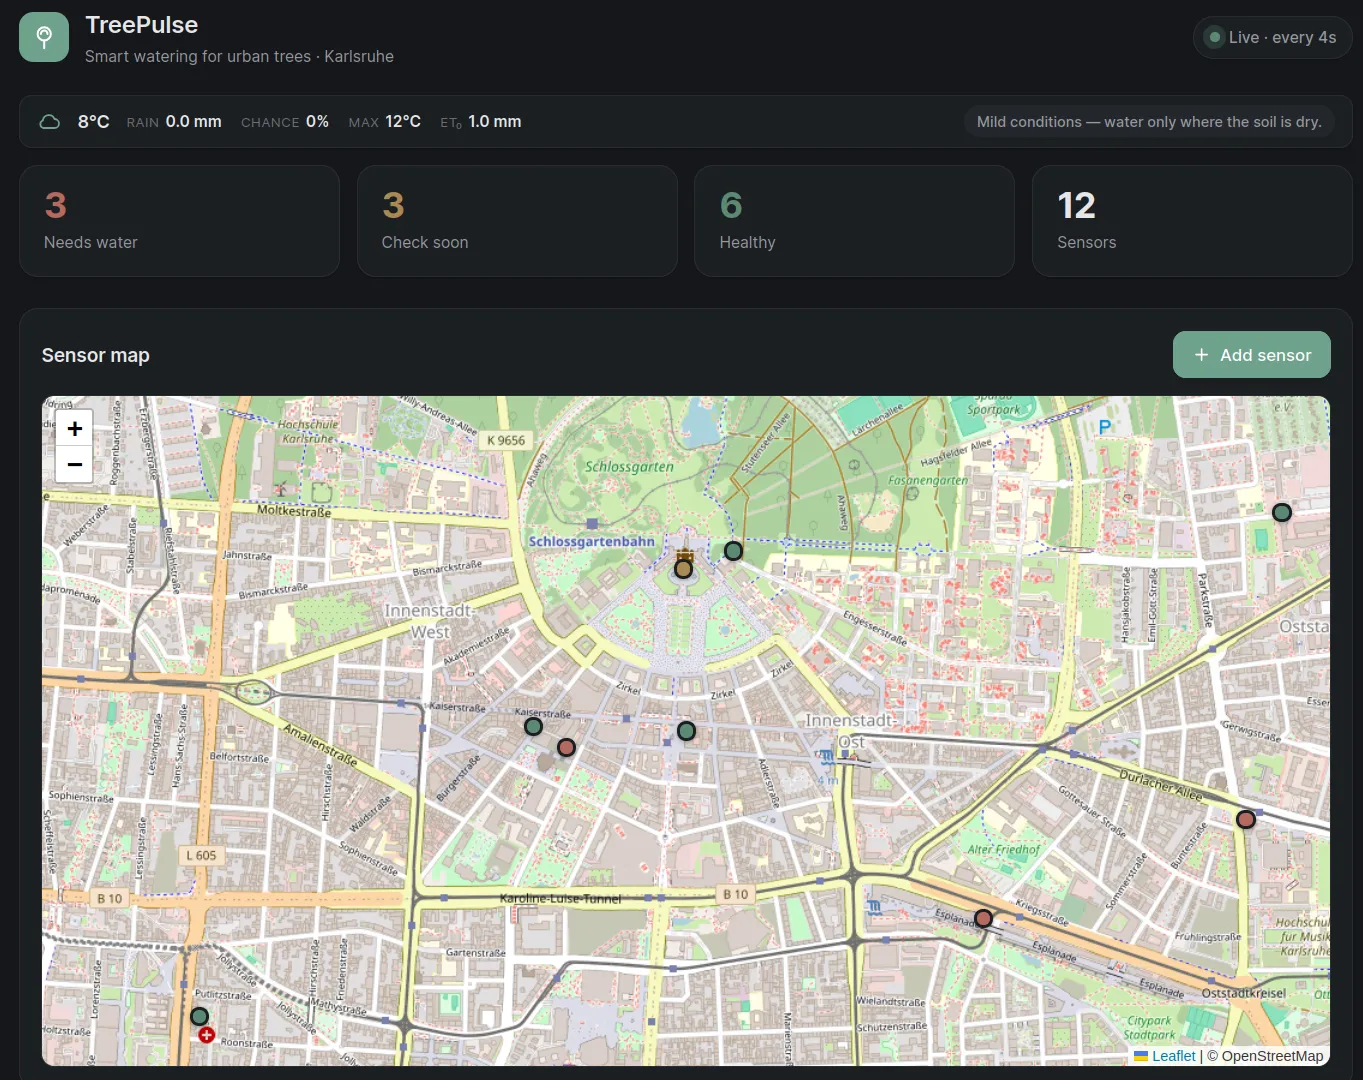
  3. Screenshot of the TreePulse dashboard with a dark theme. At the top, the weather in Karlsruhe; below it, four counters: 3 trees need water, 3 should be checked soon, 6 are healthy, 12 sensors. Below that, a map of Karlsruhe city centre with red, yellow and green dots for the sensors.

    HackXplore 2026: Smart IoT Platform for VEGA

    Concept for an IoT platform that lets Karlsruhe water its city trees as needed. Challenge set by VEGA at the HackXplore 2026 hackathon.

    IoT, MQTT, Arduino, Sensor network, Hackathon

    2026-06
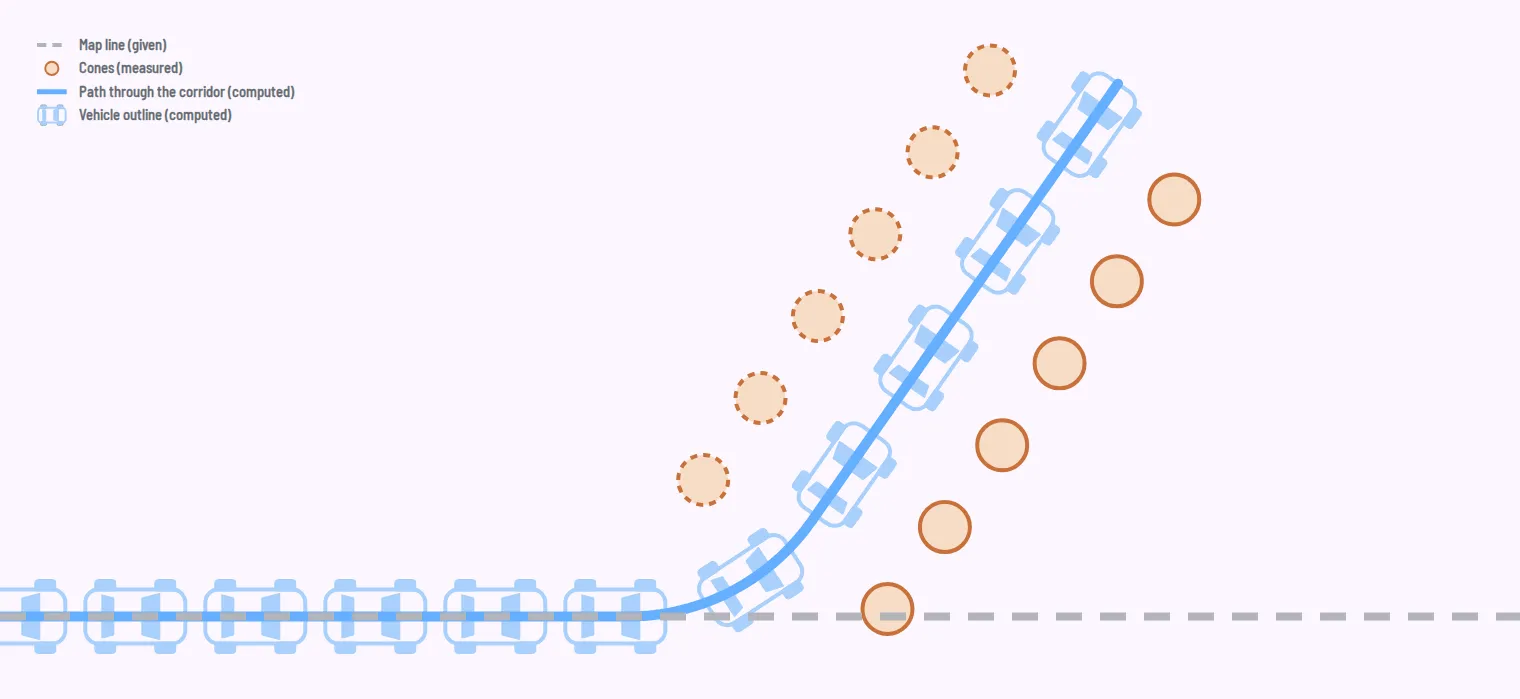
  4. Technical drawing of a cone corridor that branches off the map line at an angle, with the planned track, the transition from the map line and the vehicle outlines along the path

    Path planning for an autonomous model car

    A model car drives through a cone corridor that was detected from camera images

    Python, C++, ROS 2, Path planning, Geometry

    2026-05