Projects
2026-08
Scientific Paper - haptic feedback shared control
User study on haptic forces on a joystick that help with steering a drone
- Date
- August 2026
- Role
- Software development, data integrity, organisation
- Topics
- ROS 2, Python, Haptics, User study, Statistics, Software architecture
- Links
- Code on GitHub
What it was about
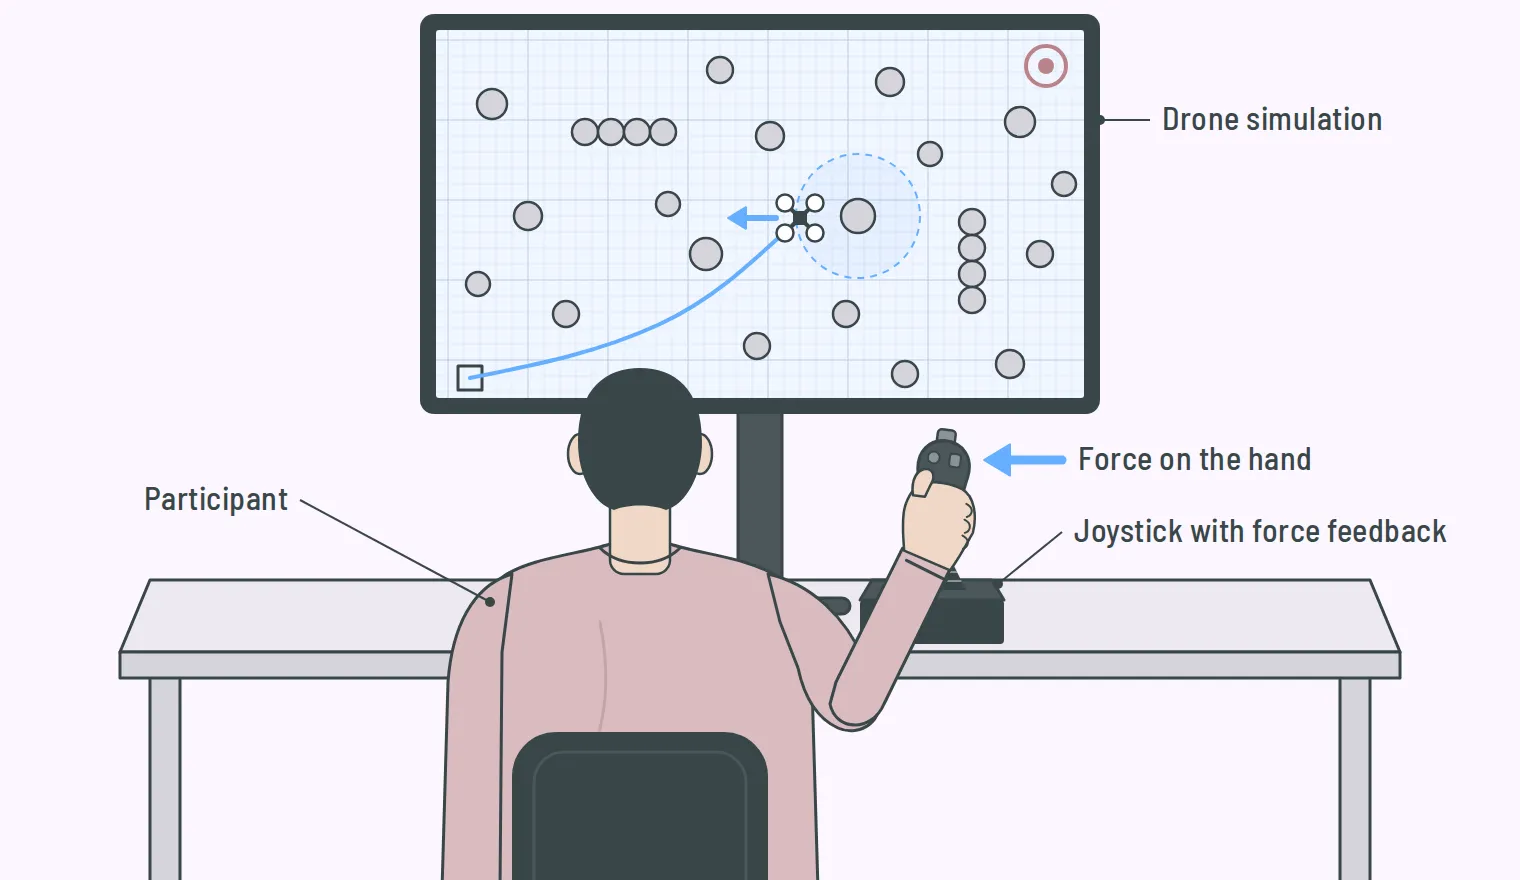
The research seminar “Cooperative and Haptic Human-Machine Interactions” was about a joystick that generates forces of its own. When the user steers a drone, for example, it pushes their hand away from an obstacle. Human and assistance system thus steer together; this is known as Haptic Shared Control. The forces are meant to bring the pilot to the goal more safely without patronising them.
My work
Within the team, I helped develop the force model and conducted and evaluated the user study. Together, we wrote the paper “Phased Haptic Shared Control for Safe and Autonomy-Preserving UAV Teleoperation” on this work. It has not been published yet.
I set up the experiment in ROS 2 so that the experimenter can control the whole procedure via a dashboard. This includes recovery methods: if part of the system crashes, no data is lost, and the participant continues from the same point.